REON-NVS: Real-Time Online Novel-View Synthesis from Sparse-View Videos
Abstract
Recent advances in online reconstruction of dynamic scenes demonstrate impressive visual quality, showing potential for real-world applications such as VR content streaming. Yet, existing online reconstruction methods still require a large number of input views and time-consuming iterative optimization. Moreover, reliable pose estimation, a prerequisite for NVS, introduces additional delay. In this paper, we present REON-NVS, a feedforward online NVS framework for sparse-view input video streams, which goes from pose estimation to novel-view reconstruction in real time. REON-NVS comprises two main components. First, our method leverages a feedforward pose estimator and mapper that replace conventional camera pose optimization pipelines. Second, we design a scene reconstructor built upon a state-space model (SSM), which efficiently synthesizes temporally consistent novel-view images by exploiting information from previous frames. To train and evaluate our approach in realistic in-the-wild streaming scenarios, we introduce a new multi-view dynamic scene dataset of 150 dynamic scenes captured with moving cameras. Extensive experiments demonstrate that REON-NVS achieves high visual quality while operating in real time (32 FPS), validating its applicability in real-world scenarios.
Method
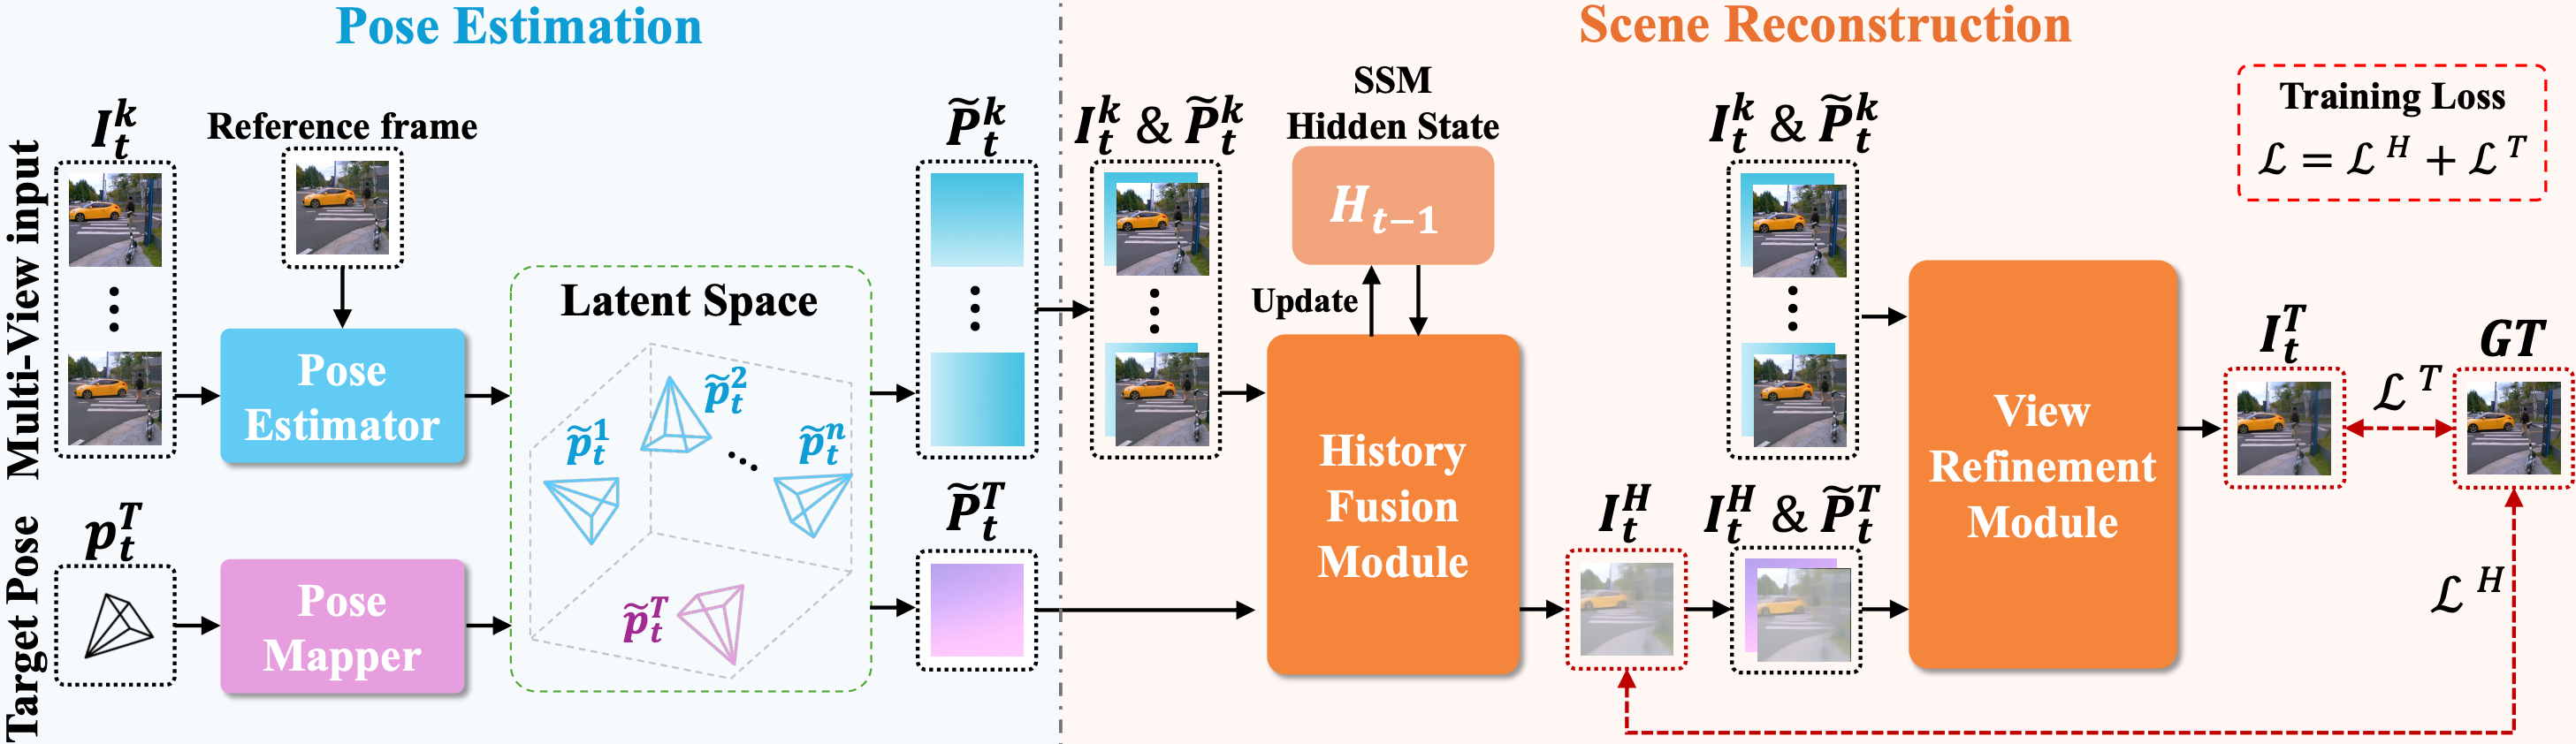
REON-NVS combines a feedforward pose estimator and mapper with an SSM-based scene reconstructor to synthesize temporally consistent novel views in real time.
Results
BibTeX
@inproceedings{kim2026reonnvs,
  title     = {REON-NVS: Real-Time Online Novel-View Synthesis from Sparse-View Videos},
  author    = {Kim, Daeyeon and Kim, Jinhyeok and Kwon, Gangmin and Shin, Seungjoo and Cho, Sunghyun},
  booktitle = {European Conference on Computer Vision},
  year      = {2026}
}